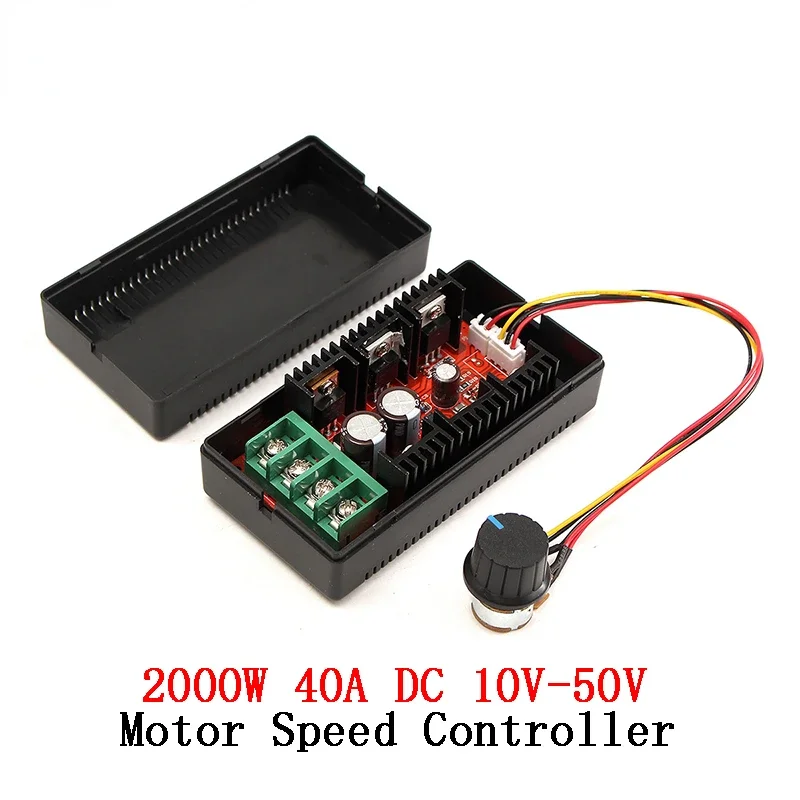
What Actually Happens When You Hook Up a 40A PWM Controller
I spent three weekends figuring this out the hard way. You grab a cheap 40A PWM DC motor speed controller off Amazon or AliExpress, wire it to your brushless or brushed motor, flip the switch, and suddenly your RC car lurches forward at half throttle while the other half feels completely dead. That is the reality before you understand what these boards actually do under the hood. A PWM motor speed controller works by rapidly switching power on and off. The ratio of on-time to the total cycle time determines the average voltage the motor sees. If the signal is on 50% of the time, the motor gets roughly half voltage. The trick is that most cheap controllers are not linear. They assume a specific input range, and they do not behave predictably outside it.
Dominate Your Robotics And Rc Projects With The 40a Pwm Dc Motor Speed Controller Control Your Motor
This guide covers the practical side. Not the theoretical side. I will tell you how to wire it, how to tune it, and what goes wrong when you ignore a few details that nobody mentions in the product description. The 40A rating is a peak number. It means the MOSFETs on the board can handle up to 40 amps for short bursts before the heatsink starts complaining. Your actual continuous draw should stay under 30A if you want the controller to last more than a few months. Thermal rolloff is real, and it happens silently. The board accepts three inputs: power (battery or wall adapter), ground, and a control signal. The control signal is typically a PWM signal from an ESC, Arduino, RC receiver, or throttle stick. The frequency matters. Most hobby controllers expect a signal between 50Hz and 490Hz. Some can handle up to 8kHz if you are driving them from a microcontroller, but go too high and the MOSFETs start switching inefficiently and the board gets warm for no reason.
Here is something beginners miss: the throttle curve on these controllers is almost never linear. A 50% duty cycle command does not produce 50% motor speed. It produces somewhere between 35% and 60% depending on load, battery voltage, and the internal pull-up resistors on the board. You have to map it yourself.
Get the Full Details
Wiring It Correctly
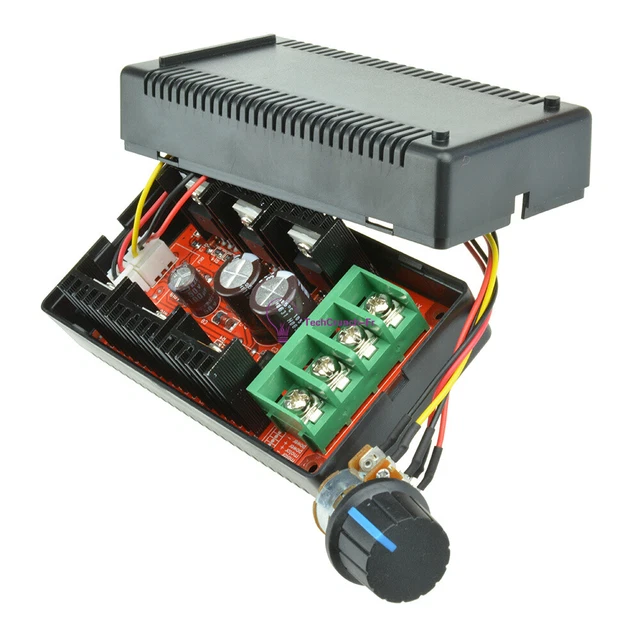
There are three terminals on every 40A PWM controller, usually labeled V+, GND, and SIGNAL or PWM. The power terminals take the battery connection. The signal terminal takes the PWM output from your controller source. Do not cross these. I learned that after frying a $12 board by accidentally feeding 12V into the signal pin instead of the power input. The internal zener diode on the signal line has a maximum rating of around 5.5V. Anything above that and it clamps, then fails, then lets the smoke out. Use proper gauge wire for the power connections. If you are drawing more than 15A, go with at least 14 AWG for the battery leads. Thinner wire creates voltage drop under load, and voltage drop makes your motor behave like it is running on a dying battery. The controller does not compensate for input sag. It only switches whatever voltage is in front of it. Ground everything to the same point. Common ground is not optional. If your microcontroller, battery, and motor share different ground references, you will see noise in the PWM signal, erratic throttle behavior, and possibly damaged pins on your controller board. One ground point, star layout if you are building something permanent.
Connecting to Common Control Sources
RC Receiver: Plug the signal wire into any channel on your receiver. Set the transmitter to exponential and dual-rate to shape the throttle curve. Most people leave this default and wonder why the motor jumps at low throttle positions. Adding 10-15% exponential smooths out the dead zone near idle. Arduino or ESP32: Generate the PWM signal using analogWrite() on most boards, or use the LEDC library on ESP32 for more precise control. Set the frequency to 50-490Hz. Map the output from 0-255 to the controller's expected pulse width range, which is usually between 1ms and 2ms. If your motor spins at full speed even at 0% command, your pulse width mapping is backwards or offset incorrectly. ESC Input: Many people use an existing ESC as the control source for a PWM speed controller. This works fine but introduces a complication: ESCs often have a built-in brake function. If your ESC outputs a braking signal at mid-throttle, the speed controller interprets it as a command and may behave unpredictably. Disable the brake function in your ESC configuration if possible.
Calibrating the Throttle Range
Every 40A PWM controller has a minimum and maximum pulse width it responds to. The standard range is 1ms (full reverse or off) to 2ms (full forward), with 1.5ms as neutral. But cheap boards vary. Some respond to 0.9ms minimum, others need 1.1ms. You need to find your board's actual range. Here is how I calibrated mine. Connected an oscilloscope to the signal line, sent 1ms pulses, watched the motor spin direction and speed, then adjusted until the motor was completely off at the minimum and full speed at the maximum. Without an oscilloscope, you can approximate using a multimeter set to measure duty cycle. Send a 1ms pulse, note the motor response, increment by 0.1ms, repeat until the motor reaches full speed. The range between off and full speed is your calibration window. This took me about 40 minutes the first time. Once you know your board's range, you can write it into your code or transmitter settings permanently and never do it again.
Heat Management and Real-World Limits
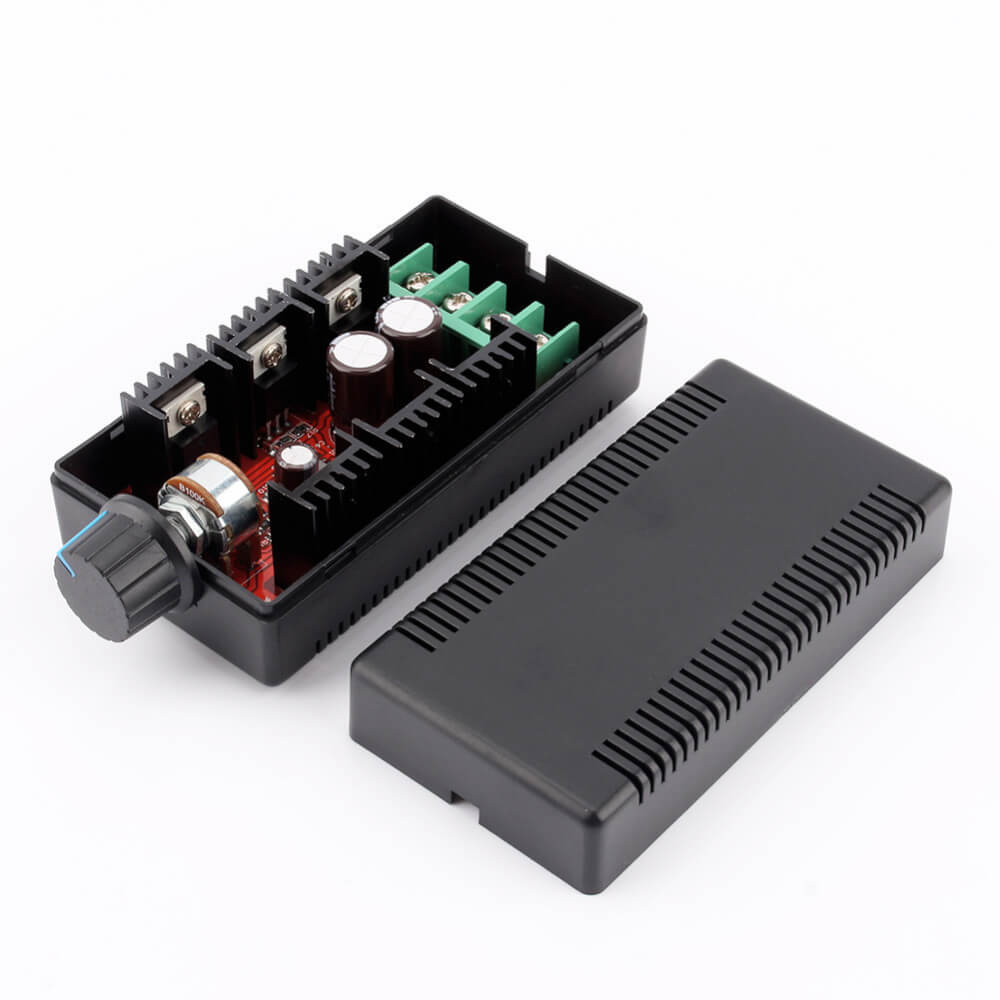
The 40A label is misleading if you think it means continuous 40A. A 40A controller without active cooling will thermal throttle at around 20-25A continuous for an extended run. The MOSFETs get hot, the internal protection circuit kicks in, and power drops. If you add a small 5V fan mounted near the heatsink, you can push closer to 30A continuous, but the fan itself draws power and adds complexity. I encountered a specific problem during a robotics competition. My robot drew about 35A for 30-second bursts during matches. The controller got hot enough to melt the heat-shrink insulation on my power wires. The workaround was straightforward but not obvious: I replaced the solder joints on the power terminals with thicker gauge wire and added a small aluminum heatsink clamp that made direct contact with the MOSFETs. The temperature dropped by about 15 degrees Celsius. Cheap fix, significant improvement. If you are building something that runs for more than a few minutes at high current, budget for thermal management from the start. It is cheaper than replacing melted plastic.
Common Mistakes That Break These Controllers
Reversed polarity: Connecting power backward destroys the board instantly. Some have reverse polarity protection, most cheap ones do not. Check your wire colors before connecting. Red is usually positive, black is ground, but not always. Signal voltage mismatch: Feeding 12V into a 5V-tolerant signal pin is the fastest way to kill these controllers. If your control source outputs higher than 5.5V, use a voltage divider or level shifter. A simple 10K and 20K resistor divider reduces 12V to about 4V, which is safe. Inductive kickback: DC motors generate voltage spikes when they stop suddenly. Without a flyback diode across the motor terminals, those spikes travel back through the controller and damage the MOSFETs. Most 40A controllers have internal diodes, but they are not always sufficient for high-inductance motors. Add an external diode rated for your current if your motor is large.
Loose connections: Vibration from RC cars and robots loosens screw terminals over time. A loose connection creates resistance, which creates heat, which creates more resistance. It is a positive feedback loop that ends in a melted terminal block. Torque your screws firmly and check them every few runs.
When a PWM Controller Is Not the Right Choice
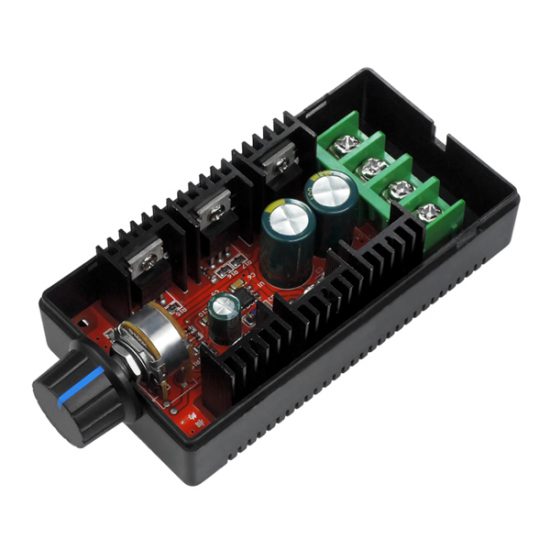
If you need precise speed control under varying loads, a simple PWM controller is not enough. It has no feedback loop. The motor speed changes with battery voltage and mechanical load. For applications that require consistent RPM regardless of load, you need a closed-loop controller with an encoder and a PID loop. The PWM speed controller is an open-loop device. It sets voltage, not speed. If you are controlling a brushless motor, this type of controller will not work directly. Brushless motors need three-phase commutation, which requires an ESC, not a PWM speed controller. These boards are for brushed DC motors only. I learned that too after ordering one expecting it to control my drone motor. It did not. For very low-power applications under 5A, a simple transistor-based circuit might be cleaner and cheaper than buying a pre-built 40A board. The extra capacity is wasted, and the board will still draw some quiescent current even when off.
My Recommended Setup for Typical RC Projects
Battery: 12V LiPo or lead-acid depending on your motor requirements. Power wiring: 14 AWG for draws up to 20A, 12 AWG for anything above that. PWM frequency: 100Hz for RC receiver control, 490Hz for Arduino if you need faster response. Signal voltage: 5V logic with a voltage divider if your source exceeds 5.5V. Heat management: passive heatsink with thermal pad contact, add a fan if running above 20A for more than 5 minutes. Calibration: find your min and max pulse widths once, save them, and use them consistently. This setup handled my RC tank project without issues for six months of regular use. The controller ran warm but never tripped thermal protection. The motor responded smoothly across the throttle range after I mapped the non-linear curve in software. Total cost for the controller board was around $8 including shipping.